Product Description of TD Series Robot Joint Actuator
The TD Series Robot Joint Actuator is a compact and lightweight integrated robotic joint actuator featuring an ultra-thin harmonic drive reducer, FOC servo controller, high-efficiency brushless torque motor, integrated brake, and high-precision multi-turn absolute encoder within a single highly integrated module. It delivers high torque density, precise motion control, and reliable performance for advanced robotic applications such as humanoid robots, quadruped robots, collaborative robots, and intelligent automation equipment.
Engineered for robotic developers and automation engineers, the TD Series provides high precision motion control, compact size, and lightweight structure, making it an ideal robotic joint actuator solution for next-generation robotic platforms.
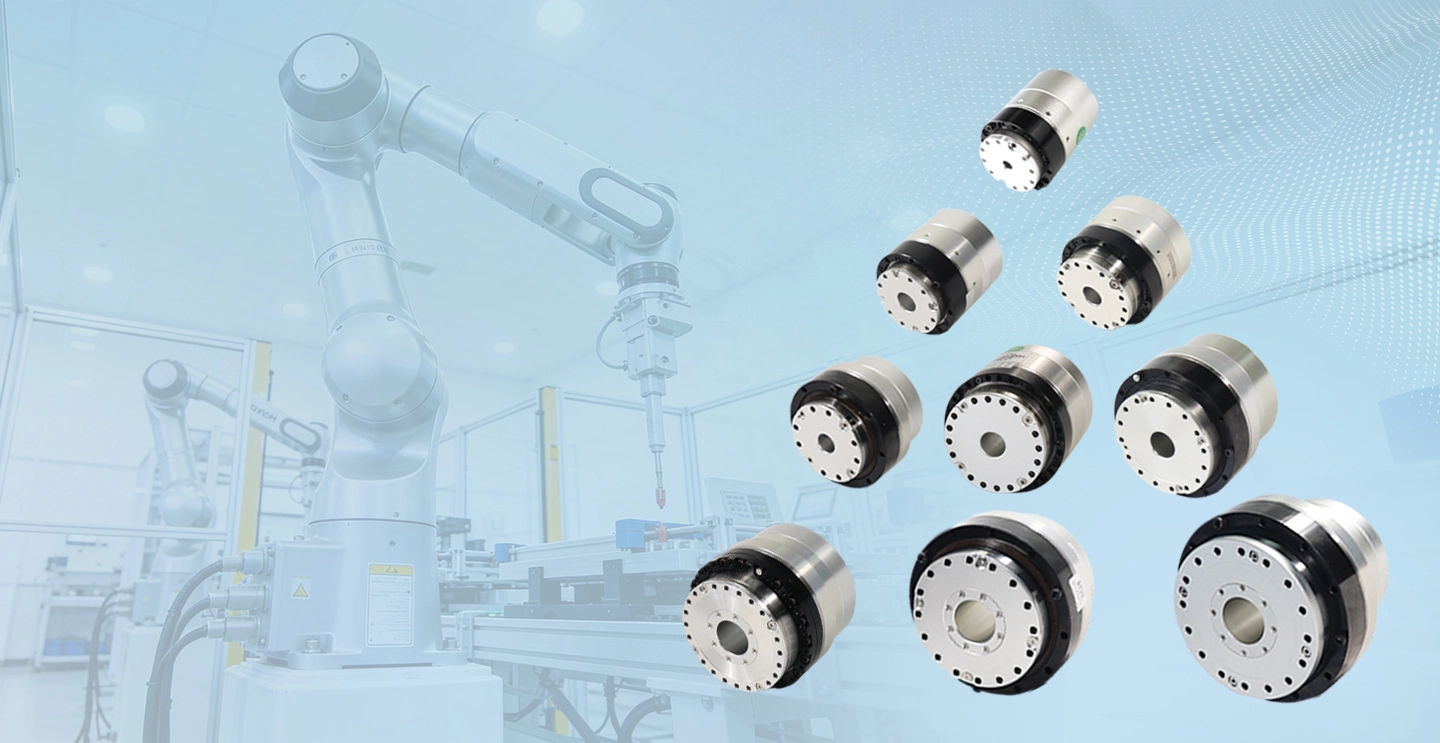
With outer diameters ranging from 40 mm to 170 mm, the TD Series allows flexible joint configuration for different robot sizes and torque requirements.

Hollow TD series joint actuators quick selection table
| Model | Ratio | Start-stop peak Torque (N.m) | Max. allowable torque at average load (N.m) | Rated torque at 2000rpm/ (reduction ratio)(Nm) | Rated speed (RPM) (With 1/2 rated torque) |
Outer diamter (mm) |
Length (mm) | Weight (Kg) |
Hole (mm) |
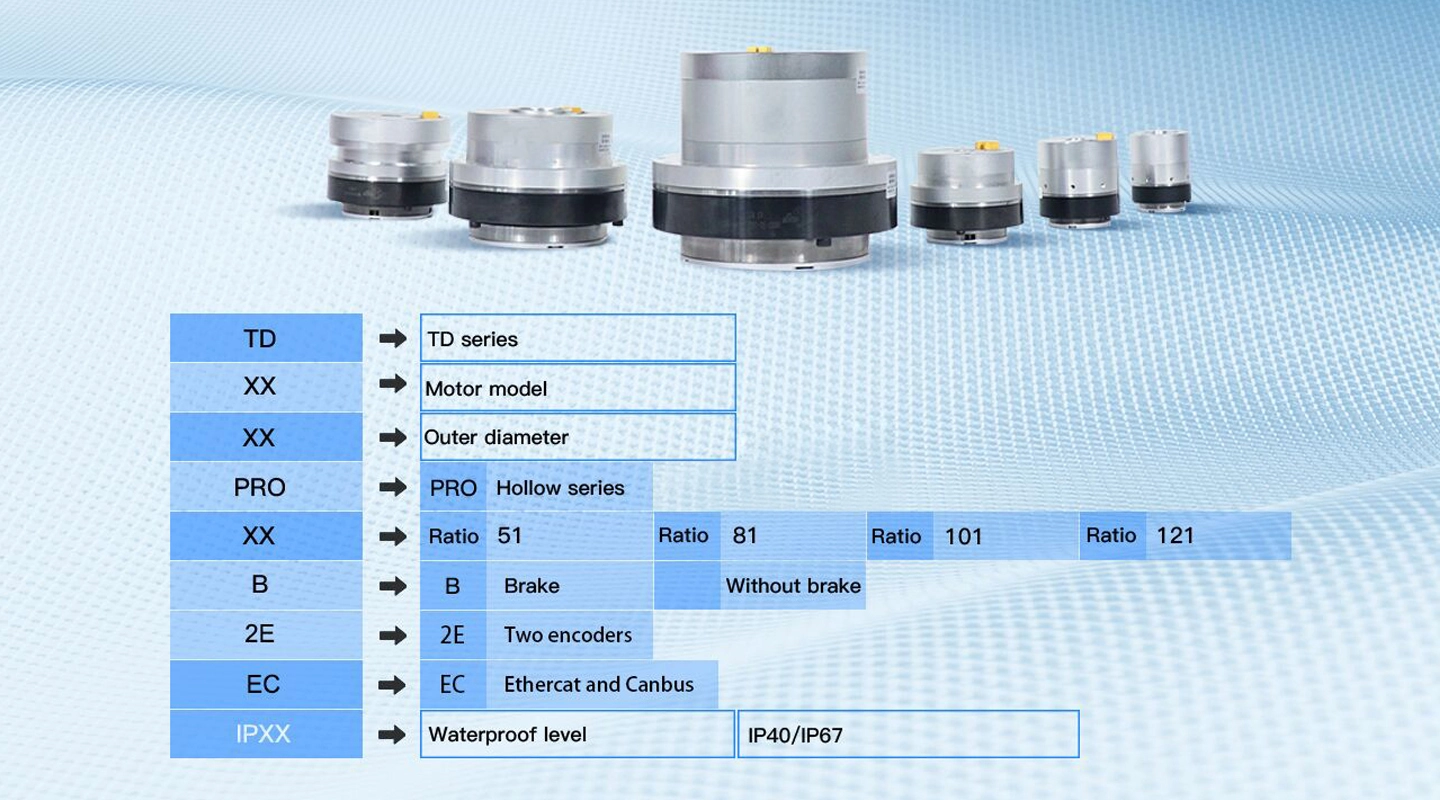
| TD-30-40-PRO-XX | 51/101 | 3.3/4.8 | 2.3/3.3 | 1.8/2.4 | 90/45 | 40 | 60 | 0.19 | 6 |
| TD-40-52-PRO-XX | 51/101 | 8.3/11 | 5.5/8.9 | 3.5/5 | 80/40 | 52 | 62 | 0.32 | 12 |
| TD-50-60-PRO-XX | 51/81/101 | 23/29/34 | 8.6/13.5/13.5 | 6.6/9.6/9.6 | 75/46/37 | 60 | 63 | 0.45 | 12 |
| TD-50-70-PRO-XX | 51/81/101 | 23/29/34 | 8.6/13.5/13.5 | 6.6/9.6/9.6 | 75/46/37 | 70 | 63 | 0.66 | 12 |
| TD-60-70-PRO-XX | 51/81/101/121 | 42/53/66/66 | 32/33/49/49 | 19.8/27.5/30/30 | 68/43/34/24 | 70 | 72.5 | 0.73 | 18 |
| TD-60-80-PRO-XX | 51/81/101/121 | 42/53/66/66 | 32/33/49/49 | 19.8/27.5/30/30 | 68/43/34/24 | 80 | 72.5 | 1.03 | 18 |
| TD-70-80-PRO-XX | 51/81/101/121 | 63/91/102/108 | 42/58/61/61 | 32/42/50/50 | 61/38/30/25 | 80 | 73 | 0.90 | 18 |
| TD-70-90-PRO-XX | 51/81/101/121 | 63/91/102/108 | 42/58/61/61 | 32/42/50/50 | 61/38/30/25 | 90 | 73.5 | 1.27 | 18 |
| TD-80-97-PRO-XX | 51/81/101/121/161 | 121/169/194/207/217 | 68.5/107/133/133/133 | 48/78/84/84/84 | 54/35/27/23/17 | 97 | 85.5 | 1.50 | 27 |
| TD-80-110-PRO-XX | 51/81/101/121/161 | 121/169/194/207/217 | 68.5/107/133/133/133 | 48/78/84/84/84 | 54/35/27/23/17 | 110 | 85.5 | 2.06 | 27 |
| TD-100-120-PRO-XX | 51/81/101/121/161 | 267/376/411/436/459 | 133/206/267/267/267 | 94/146/169/169/169 | 44/29/22/18/12 | 120 | 100.5 | 2.52 | 32 |
| TD-100-142-PRO-XX | 51/81/101/121/161 | 267/376/411/436/459 | 133/206/267/267/267 | 94/146/169/169/169 | 44/29/22/18/12 | 142 | 100.5 | 3.96 | 32 |
| TD-110-170-PRO-XX | 51/81/101/121/161 | 497/641/702/762/800 | 242/351/460/557/557 | 169/255/328/363/363 | 22/15/12/10/7 | 170 | 121.7 | 6.84 | 40 |
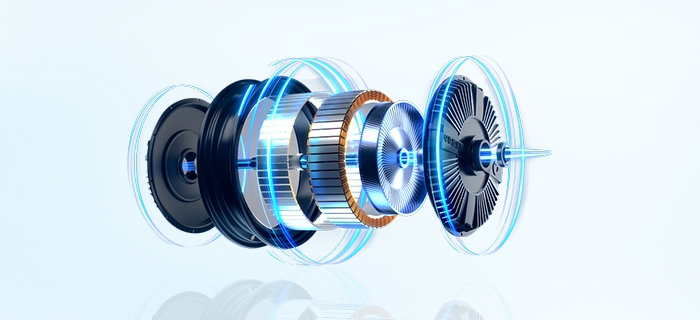
COMPACT STRUCTURE-EIGHT
KEY COMPONENTS
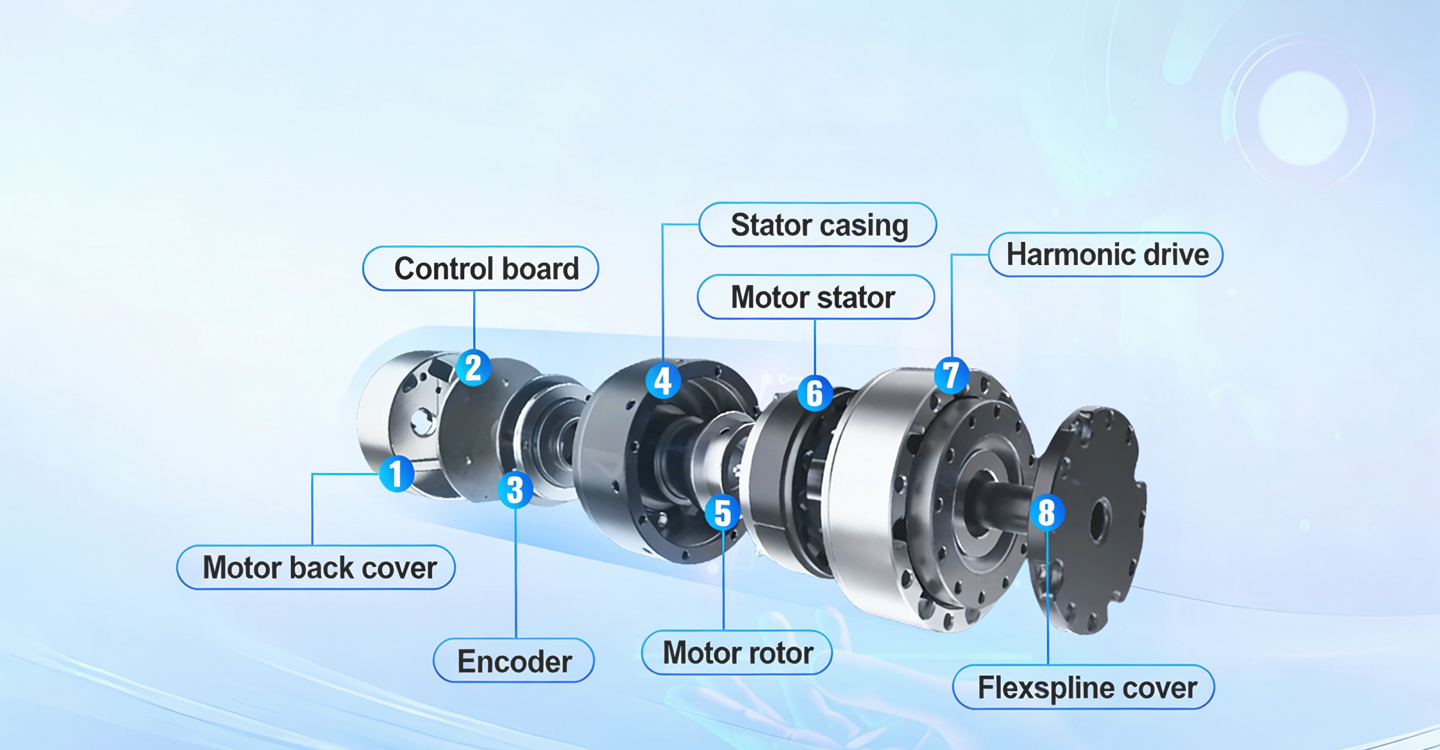
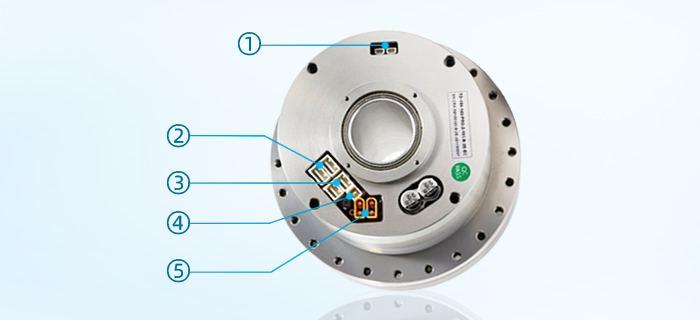
① Motor back cover ②Control board ③Encoder ④Stator casing ⑤Motor rotor ⑥Motor stator ⑦Harmonic reducer ⑧Flexspline cover
Product Features
Avatar TD Series robot joint motors have compact stucture with light weight, high torque, more usable.
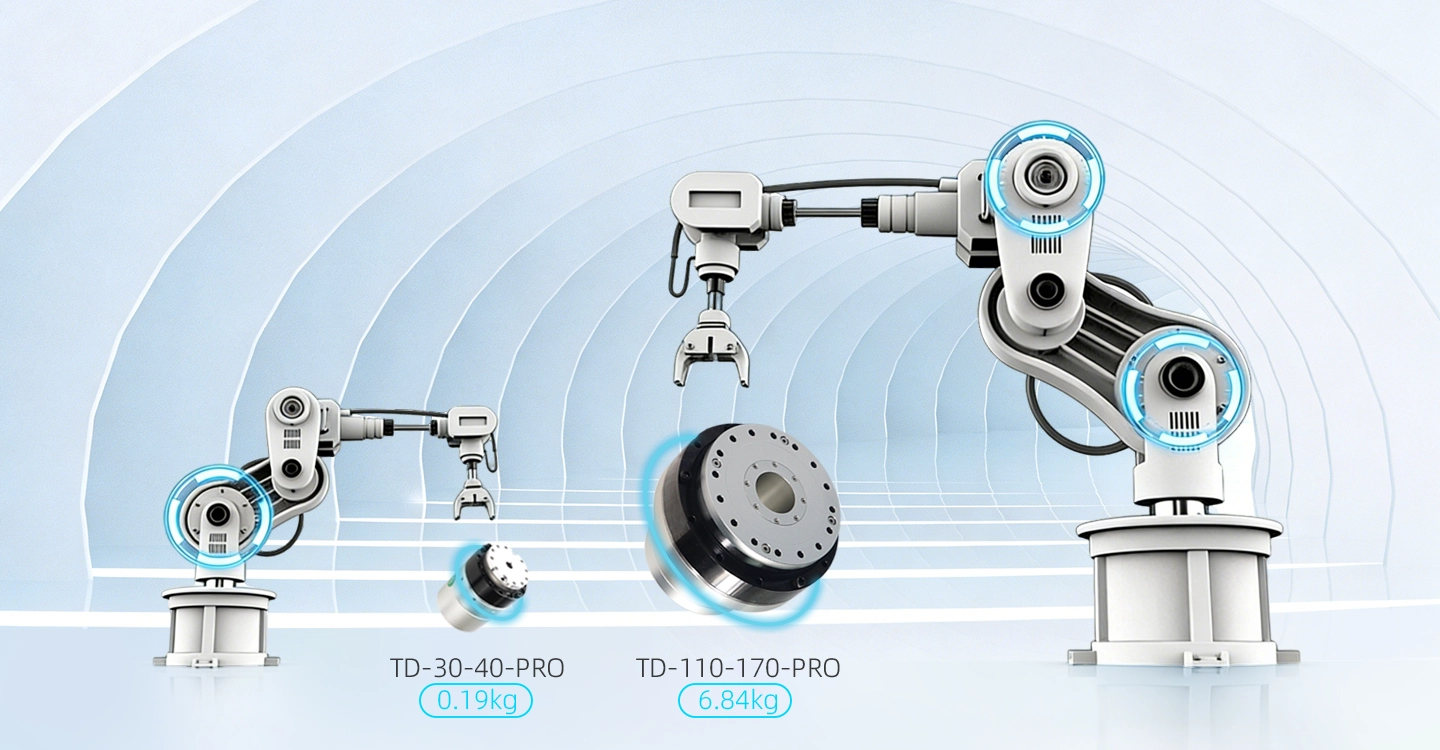
1.The smallest type of TD robot joint module has outer diameter of 40mm and weight only 0.19kg. The weight is less than 1/3 of the ordinary joint motors which greatly reduce the operation energy consumption.
2.The largest TD robot joint module actuators, the TD-110-170-Pro-121, has a torque of up to 363Nm.
ULTRA-LIGHT WEIGHT
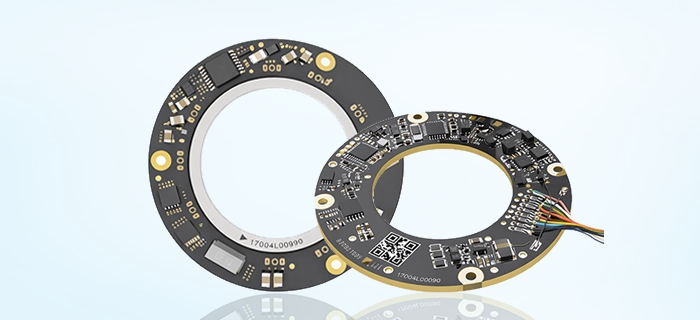
High-Precision Encoder System
1. Advanced eddy current encoder technology ensures highly stable and accurate position feedback for robotic motion control.
2. 17-bit multi-turn absolute encoder (CAN version) with positioning accuracy up to 0.05°, enabling precise joint positioning.
3. 16-bit + 18-bit dual encoder configuration (EtherCAT version) provides enhanced feedback redundancy and improves positioning accuracy to better than 0.03°, ideal for high-precision robotic joint control.
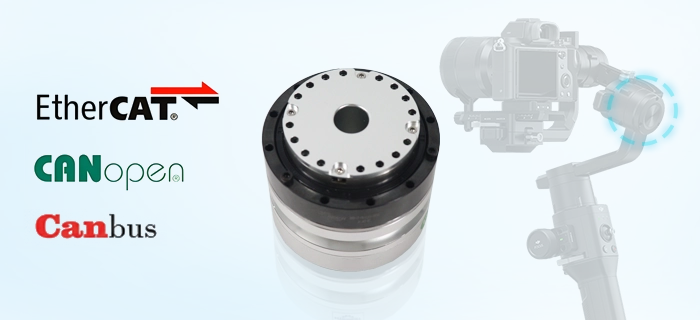
Multiple Communication Protocol
1. EtherCAT high-speed industrial communication protocol for real-time motion control in advanced robotic systems.
2. CANopen protocol for reliable and flexible integration with robotic controllers.
3. CAN Bus communication supporting stable multi-axis robotic actuator networks.
4. Self-developed force-control servo driver, enabling precise torque control for advanced robot joint actuator applications.
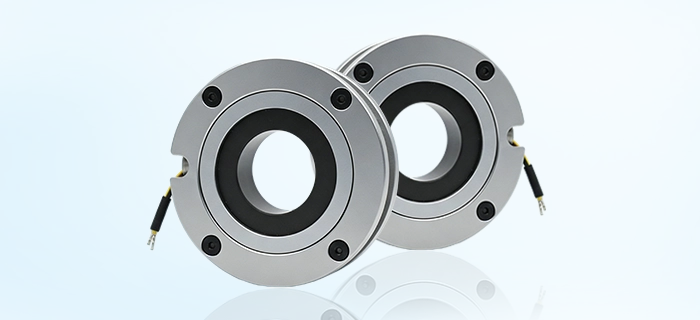
Low-Noise Permanent Magnet Brak
1. Integrated permanent magnet brake designed for robotic joint safety and reliability.
2. Rapid motor stop capability for fast response during emergency or control commands.
3.Automatic position locking when power is suddenly lost, ensuring stable joint holding.
4.Low-noise brake design, improving overall operational smoothness of the robotic actuator.
Peak Torque Density > 220 Nm/k
1. High magnetic saturation alloy materials to maximize electromagnetic performance.
Automotive-grade anti-static protection and military-grade anti-vibration design for improved durability.
2. Block-type stator winding structure to enhance motor efficiency and torque output.
3. Optimized large air-gap rotor design to improve torque density and dynamic performance.
4. Lightweight actuator housing reducing overall robotic joint weight.
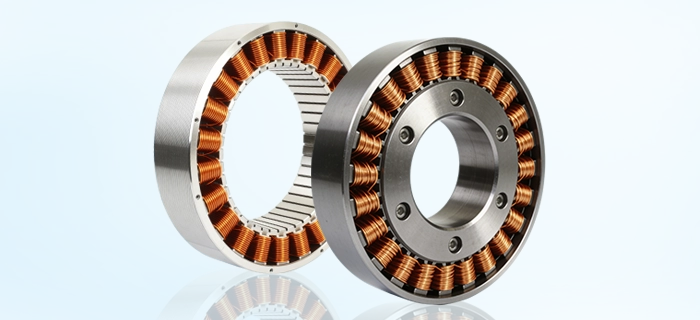
High-Torque Density Frameless Motor
1. High-torque-density frameless motor design delivering greater output performance with lower power consumption.
2. Ultra-lightweight motor structure optimized for compact robotic joint actuator modules used across multiple robotic platforms.
Optimized Interface Design
1. Compact and standardized actuator interface, enabling easier integration into robotic joints and automation equipment.
2. Modular design architecture compatible with different robotic systems and actuator configurations.