
Y-series joint actuators adopt harmonic gear reducers characterized by light weight and high output torque, combined with the brush-less DC motor independently developed by our company and encoder, to achieve unprecedented flat shape and lightweight transmission.
Y-series solid joint actuators enjoy higher rigidity and stable positioning accuracy even under heavy load, and provide better structural reliability, better load capacity, and cost efficiency.
They are popular for industrial automation projects and heavy-load equipment.
Y-series solid joint actuators enjoy higher rigidity and stable positioning accuracy even under heavy load, and provide better structural reliability, better load capacity, and cost efficiency.
They are popular for industrial automation projects and heavy-load equipment.
Compact SOLID Robot Joint Actuator
Power supply 48VDC
Support RS485 or CAN
5~135Nm Rated torque
OD70mm
OD80mm
OD90mm
OD110mm
OD142mm
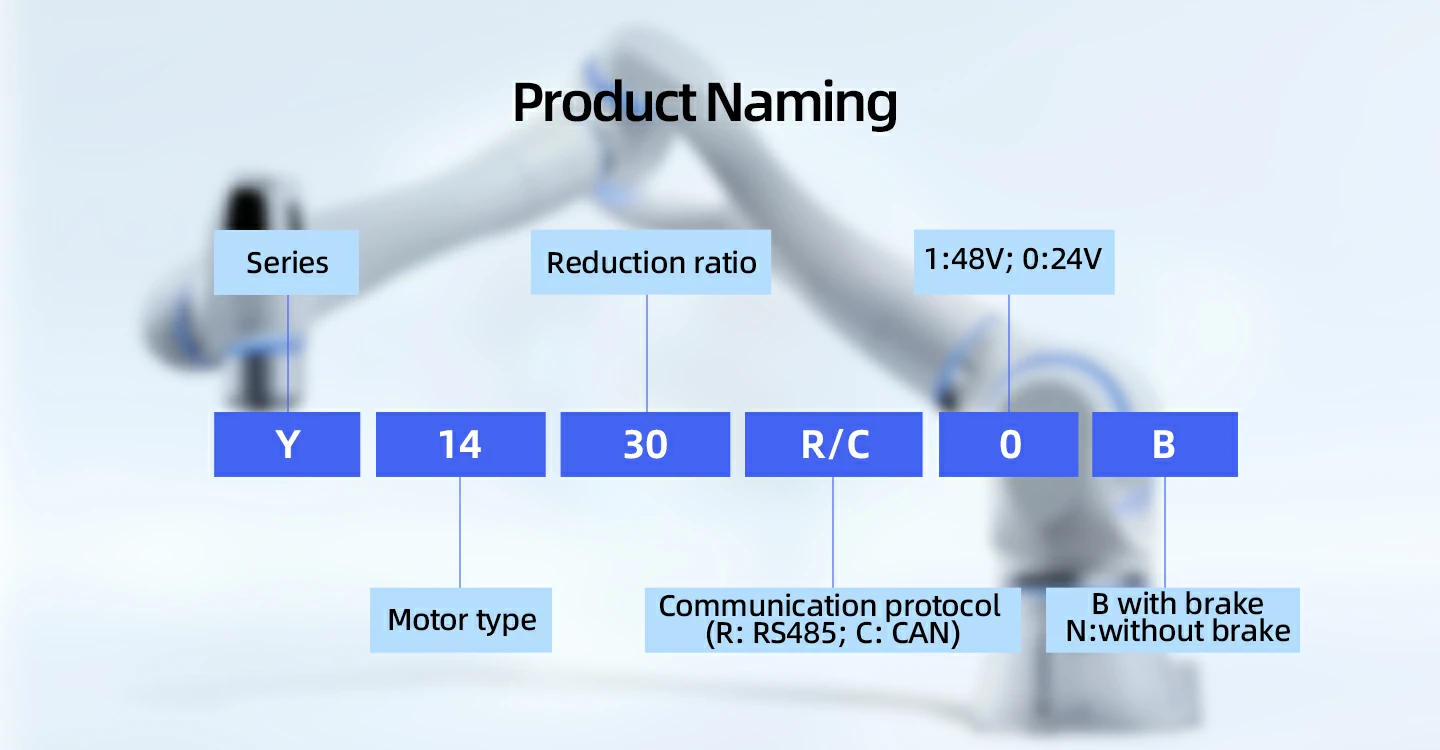
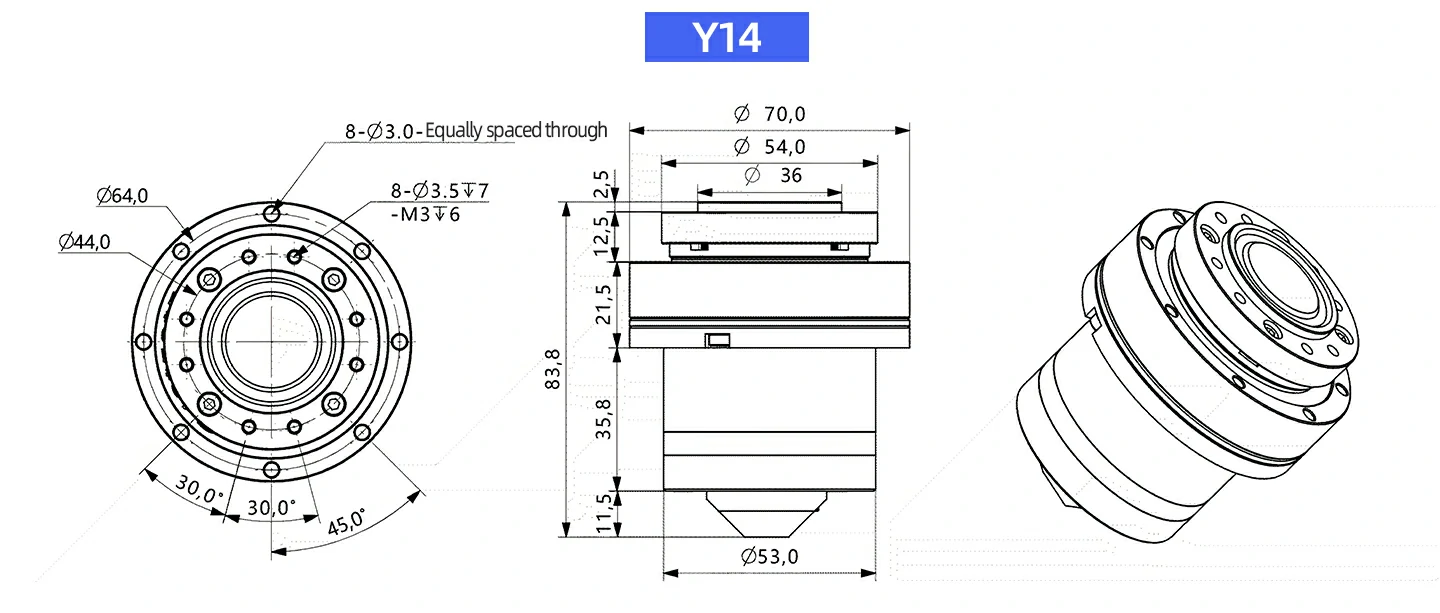
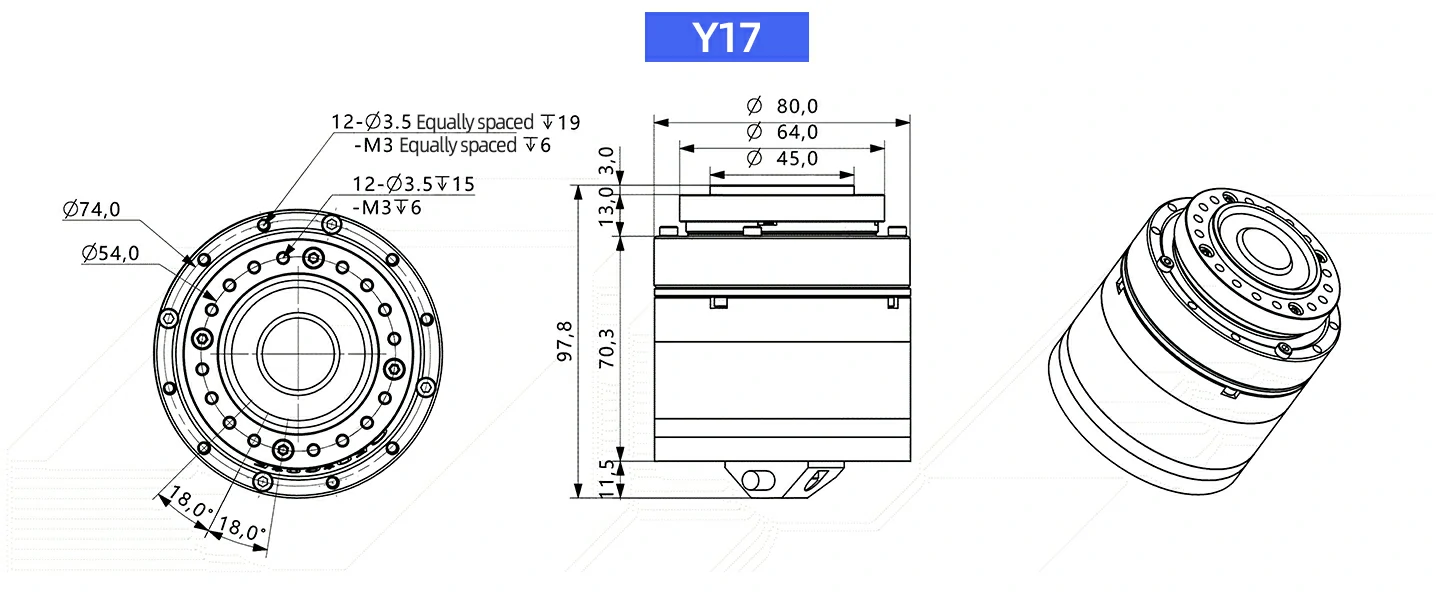
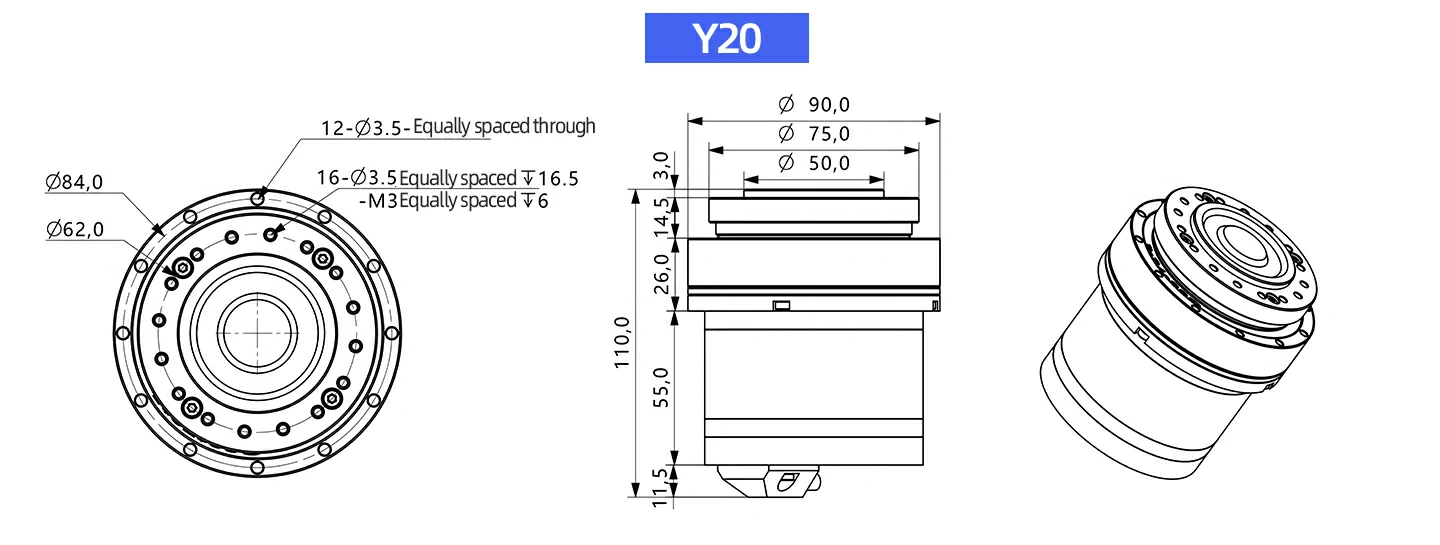
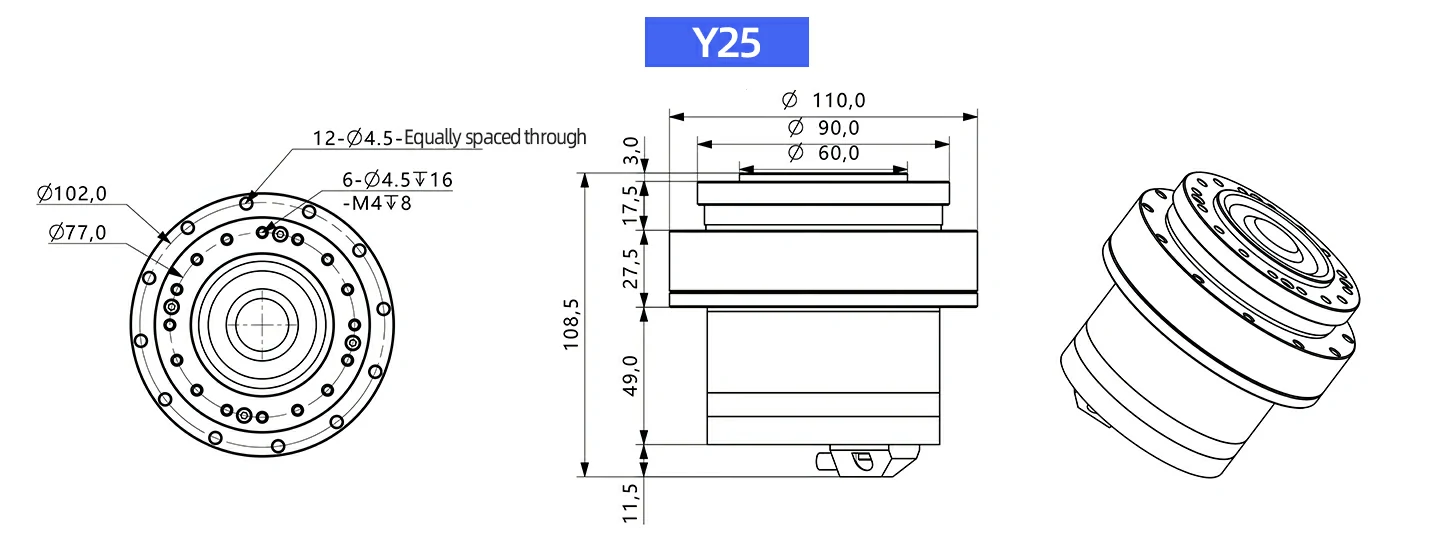
Y series joint actuators quick selection table
| Model | Y14 | Y17 | Y20 | Y25 | Y32 |
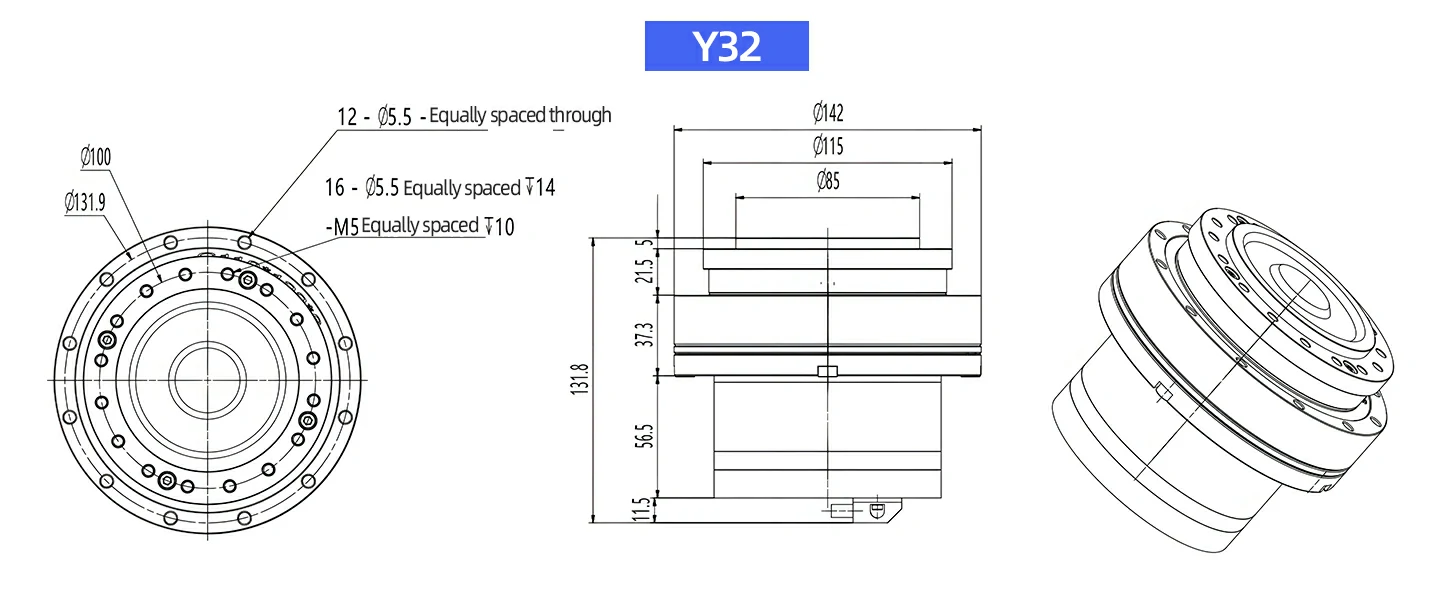
| Size | OD70*L83.8mm | OD80*L97.8mm | OD90*L110mm | OD110*L108.5mm | OD142*L131.8mm |
| Rated torque | 5/7/10/14Nm | 13/21/34/43Nm | 20/44/61/64Nm | 27/52/73/91Nm | 38/63/101/135 |
| Rated speed | 0~55/ 0~32/ 0~20/ 0~16rpm | 0~66.6/ 0~40/ 0~25/ 0~20rpm | 0~66.6/ 0~40/ 0~25/ 0~20rpm | 0~66.6/ 0~40/ 0~25/ 0~20rpm | 0~50/ 0~30/ 0~18.7/ 0~15rpm |
| Weight | 0.7kg | 1.3kg | 1.7kg | 2.3kg | 4.5kg |
| Communication | CAN/RS485 | ||||
Product Features
Super Flat Shape And Lightweight
5~135Nm Rated torque
Weight from 0.7kg to 4.5kg
Motor, Drive, Gearbox and Encoder in One Compact Unit
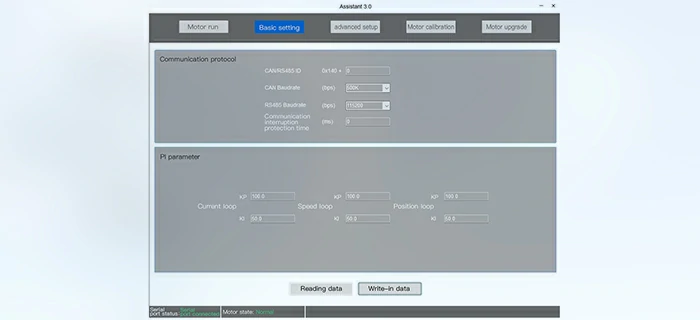
Support RS485 / CAN Protocol
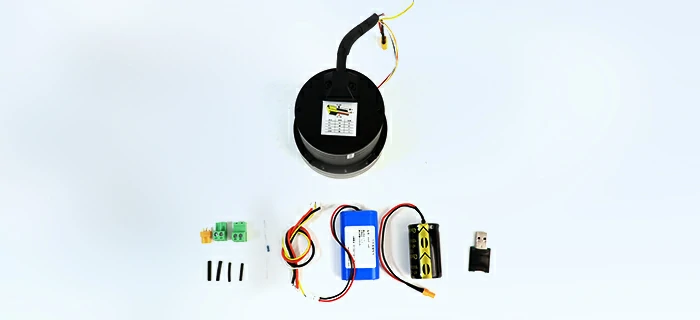
The RS485 Robot joint actuators connects to the host through the USB to RS485 device, and the CAN joint connects to the USB to serial port device through the 4p communication cable.
Strong Impact Resistance
The resistance performance of the actuator is relatively strong, and the impact acceleration can reach 300m/s2.
Vibration Resistance
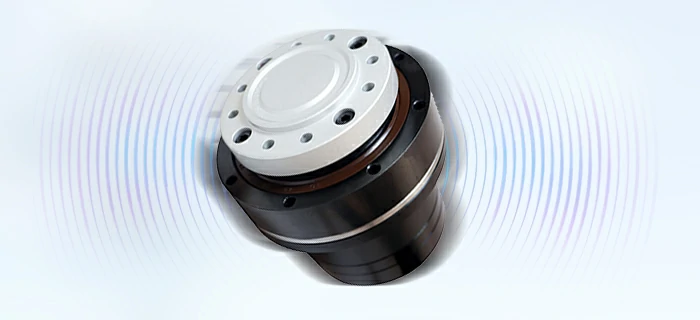
The actuator is subjected to 2H vibration test, and the vibration acceleration is 25m/s2 (frequency 10-400Hz).
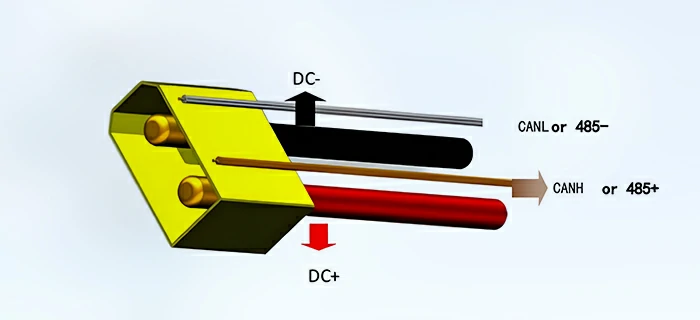
Simple interface design
| Definition | Wire color | Wire diameter | Quantity | Power |
| DC+ | Red | 18AWG | 1 | Positive |
| DC- | Black | 18AWG | 1 | Negative |
| CANH/485+ | Yellow | 22AWG | 1 | H/+ |
| CANL/485- | White | 22AWG | 1 | L/- |
Product Drawing