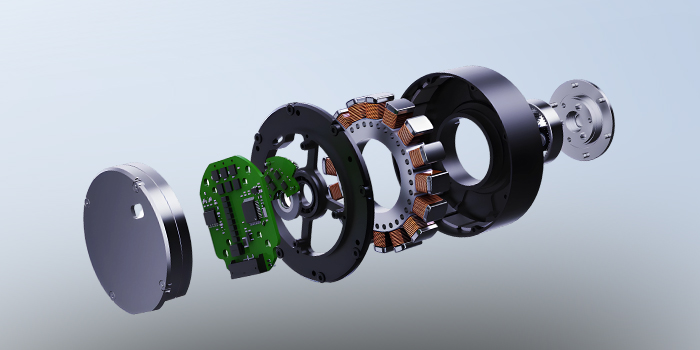
The PL series QDD planetary joint module is an integrated joint component comprising a high-torque-density motor, a low-reduction-ratio planetary gearbox, dual encoders, and a drive control system. By utilizing a low-reduction-ratio planetary gearbox, it achieves high-transparency force control, combining the compliance of direct drive with the high torque output of a gearbox.
Max rated torque: 96NM
Rated Speed : 50RPM
Rated Voltage: 48VDC
Communication: EtherCAT,CiA402 Protocol
Product description
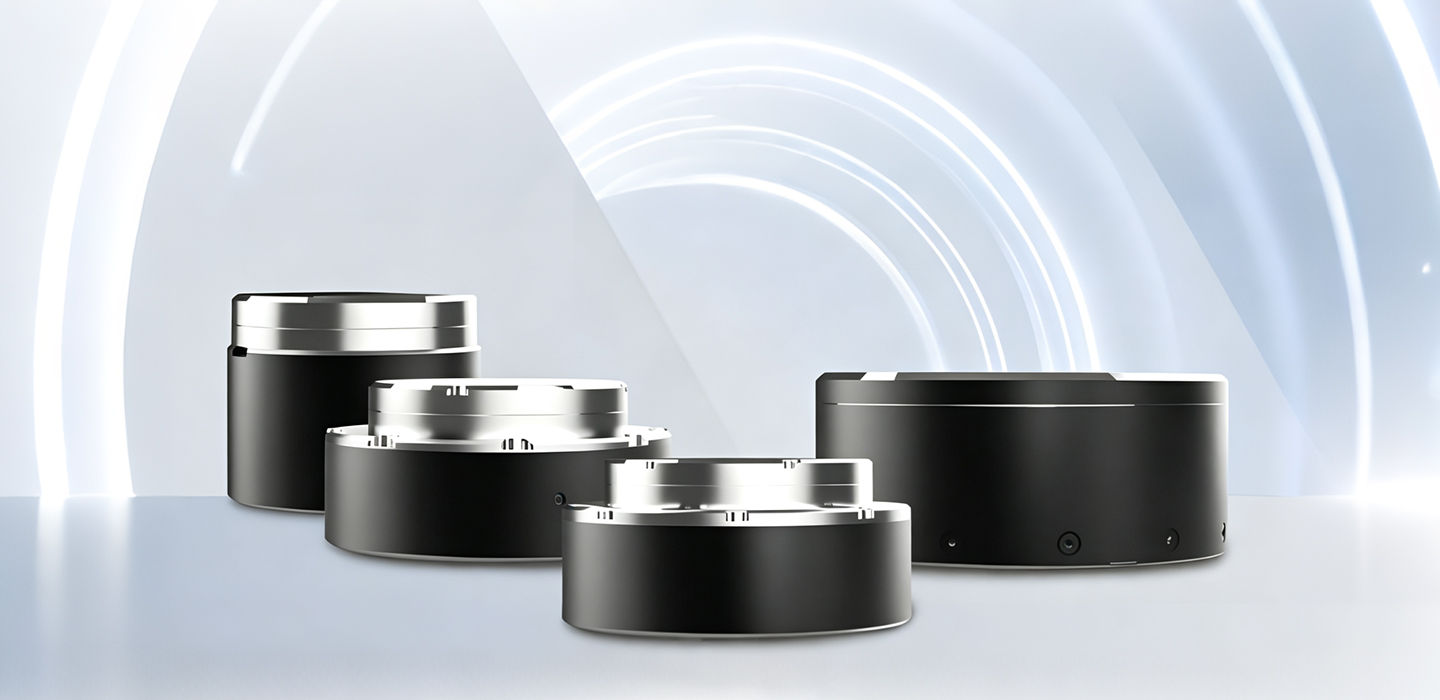
The PL series QDD planetary joint module is an integrated joint component comprising a high-torque-density motor, a low-reduction-ratio planetary gearbox, dual encoders, and a drive control system. By utilizing a low-reduction-ratio planetary gearbox, it achieves high-transparency force control, combining the compliance of direct drive with the high torque output of a gearbox; it serves as a core solution for high-dynamic lower-limb joints in legged and humanoid robots.
Product structure
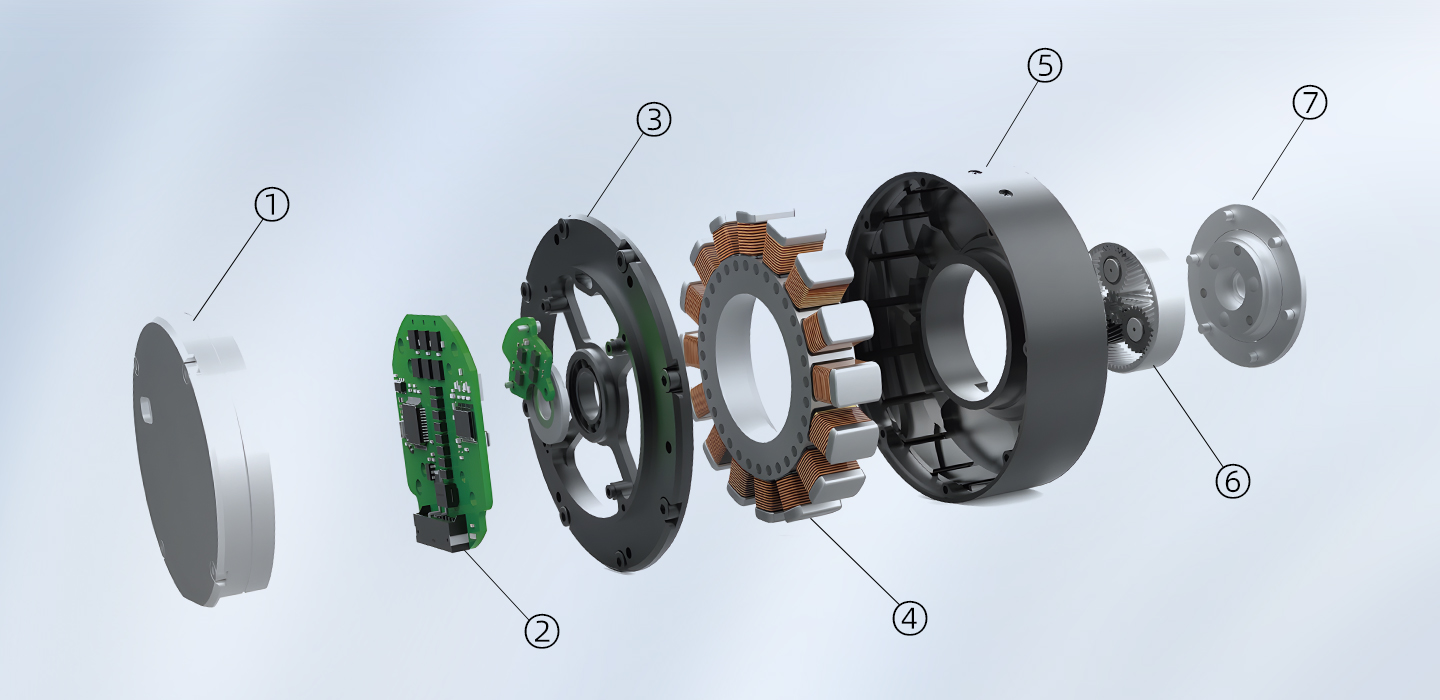
①Motor Back Cover ②: PCB driver board ③ Encoders ④Motor ⑤ Bearing⑥Planetary gear reducer ⑦Output flange
Product Features
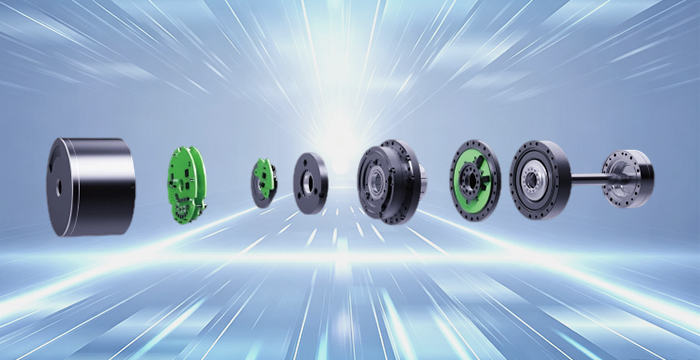
Flat compact& impact-resistant
Flat, compact, impact-resistant quasi-direct-drive planetary joint module: thin-profile integrated design, high torque density, high backdrivability, and rugged planetary gearing for dynamic legged and collaborative robotic applications.
Low inertia,&high precision
Low-inertia, high-precision quasi-direct-drive planetary joint module: lightweight rotor and optimized planetary reduction for fast dynamic response, combined with high-resolution encoding and rigid gearing for accurate positioning and transparent force control.
Back-driving intrinsically safe
Backdrivable and intrinsically safe quasi-direct-drive planetary joint module: low-ratio QDD architecture enables external backdriving, transparent force sensing, and inherent compliance for safe human-robot interaction and collision-tolerant operation.
High response speed
High-response quasi-direct-drive planetary joint module: low-inertia rotor and short transmission chain enable millisecond-level torque response, high-bandwidth force control, and stable dynamic tracking for legged and collaborative robotics.